Seeking roles in embodied AI · Research & Engineering求职方向:具身智能研究/研发 · VLA 与机器人学习

Ao Li李敖

PhD Researcher · University of Bristol布里斯托大学 · 博士研究生

Tactile sensing in robotics机器人触觉感知

I study how people explore textures by touch and how robots can use similar movements. My current project adds tactile images to π0.5-DROID.我研究人是怎么用手摸出纹理差别的,以及机器人怎样用类似的动作辨别纹理。最近也在做 π0.5-DROID 的触觉图像适配。

Current project: tactile inputs for π0.5-DROID近期项目:为 π0.5-DROID 接入触觉图像

Portrait illustration肖像插画

Selected projects精选项目

Current work近期项目

My current projects focus on visuotactile VLA and composite inspection. They build on my work on tactile exploration.目前主要在做视触觉 VLA,也在推进复合材料检测。下面还有支撑这两项工作的触觉探索研究。

Bristol-VLABristol-VLA 项目

Fine-tuning π0.5-DROID with tactile images用触觉图像微调 π0.5-DROID

I lead the VLA workstream, covering demonstration data, policy fine-tuning and deployment interfaces. I work with colleagues on the hardware. For the tactile runs, we combine two tactile RGB images into a single third input for π0.5-DROID, alongside the front and wrist camera views.我牵头做 VLA 这部分,负责示教数据、策略微调和部署接口,硬件则和同事一起做。用到触觉的训练里,我们把两路触觉 RGB 图像合成一张,作为 π0.5-DROID 的第三路图像输入,和前视、腕部相机的画面一起送进模型。

VLA → VTLAInput adaptation · schematic输入适配 · 概念示意
My role我的角色
Project Lead · VLA Development项目负责人 · VLA 研发
Research setting研究环境
Bristol Robotics Laboratory
Status进展
3 fine-tunes complete; robot comparison pending三组微调已完成,真机对比待做
  1. 01

    Prepare demonstrations整理多模态示教

    30 demonstrations · 8,116 selected frames30 段示教 · 筛选后 8,116 帧

    Implementation展开技术细节

    Four RGB streams capture front, wrist and two tactile views alongside robot state and gripper intent. Rule-based checks retain 253 continuous segments for the visual and tactile baseline experiments.四路 RGB 记录前视、腕部和双路触觉,同时保存机器人状态与夹爪意图。通过规则校验,为视觉基线及触觉版本保留 253 个连续片段。

    Franka / ZED 2i / D435 / tactile RGB

  2. 02

    Adapt the VLA policy微调 VLA 策略

    3 independent runs · 5,000 steps each3 组独立实验 · 各 5,000 步

    Implementation展开技术细节

    Native π0.5-DROID is adapted with LoRA. Two tactile RGB images share a third policy image slot; training and inference use the same adapter. The three runs cover visual, visual–tactile and reviewed-export data.基于原生 π0.5-DROID 进行 LoRA 微调。双路触觉 RGB 合成为策略的第三路图像,训练与推理共用适配器;三组实验分别采用视觉、视觉触觉和人工审核导出数据。

    OpenPI / LoRA / H15 / 8× H100 access

  3. 03

    Prepare deployment衔接推理与部署

    RTX 5090 · consistent policy inputsRTX 5090 · 一致的策略输入

    Implementation展开技术细节

    An RTX 5090 hosts the documented OpenPI inference setup. Each checkpoint must be deployed with its matching image composition and normalisation. The robot platform uses native libfranka teleoperation and a DROID impedance-control interface.在 RTX 5090 上搭建 OpenPI 推理环境,部署时配套使用 checkpoint 对应的图像合成方式和归一化文件。机器人平台使用原生 libfranka 遥操及 DROID 阻抗控制接口。

    OpenPI / libfranka / checkpoint + adapter

  4. 04

    Design the robot comparison准备真机对比评测

    Shared red-cube protocol · in preparation统一红方块任务 · 正在准备

    Implementation展开技术细节

    The planned comparison fixes the setup, reset and success criteria, then records every trial and intervention. Data checks and completed training are documented; a comparable closed-loop trial set is still outstanding.计划固定实验环境、复位条件和成功判据,逐次记录试验及人工干预。数据检查与训练完成已有记录,可比较的真机闭环试验集仍待完成。

    Fixed conditions / trial records / robot evaluation

The dataset contains 30 demonstrations.数据集包含 30 段示教。

Read the full VLA case study查看完整 VLA 项目案例
Other projects其他项目

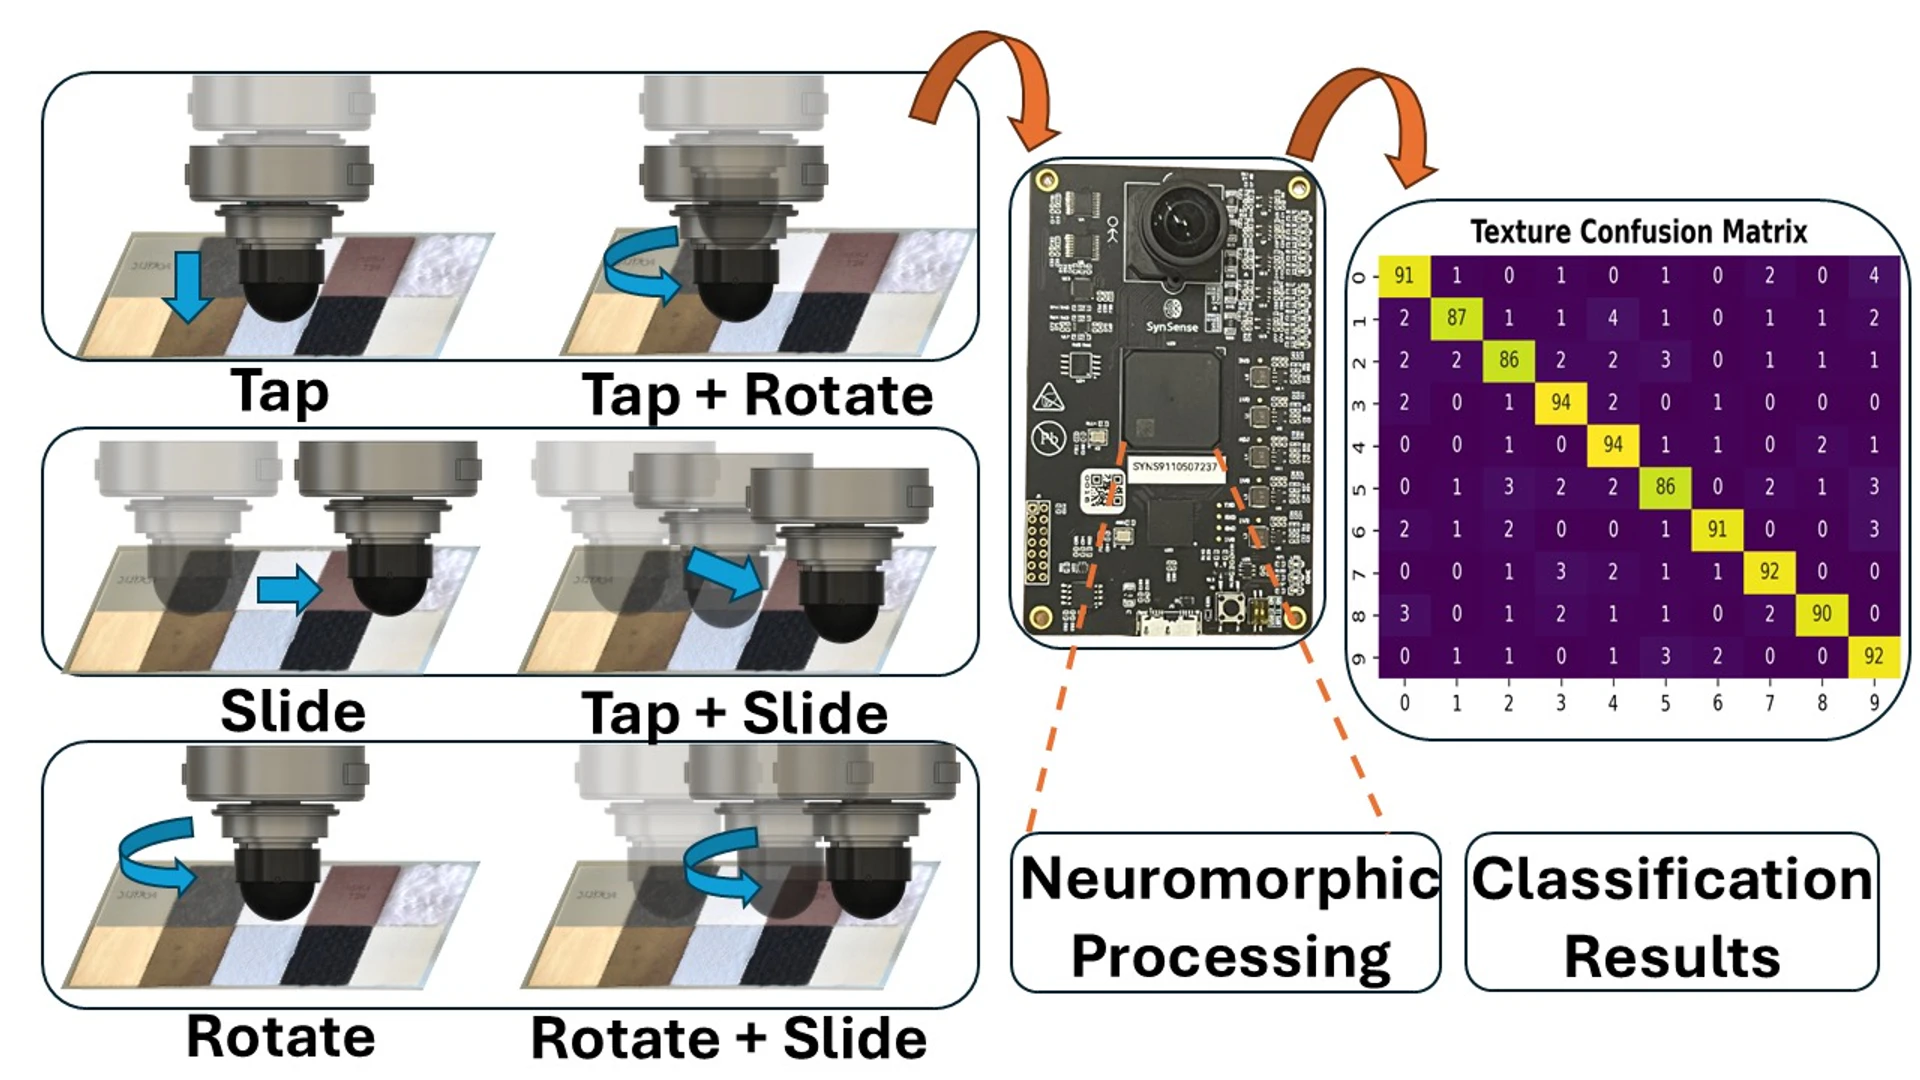
Published research figure showing NeuroTac exploratory motions, tactile sensor and classification experiments
01 / NEUROMORPHIC TOUCHPublished research已发表研究
Robotics机器人

Learning how to explore by touch触觉探索策略与纹理识别

How do touch speed and exploratory movements change what people and robots learn about texture?通过人类与机器人实验,比较触摸速度、接触力和探索动作对纹理感知的影响。

My contribution我的工作
First author of the human exploration-speed study; equal contributor to the robotic movement study.Humanoids 速度选择研究第一作者,IROS 机器人探索动作研究共同一作。
Status目前进展
Published · Humanoids & IROS 2025已发表 · Humanoids、IROS 2025
Two published studies on speed selection and movement strategies for texture perception.两项研究已发表,分别建立速度选择模型、比较机器人探索动作的识别表现。
More about this work展开项目介绍

Studies velocity modulation and compound exploratory motions to improve texture discrimination under realistic contact variation.我通过人类触摸实验和神经形态机器人实验,分析速度与复合动作对纹理识别的影响。

MODEL / INSPECTION LOOP模型 / 检测流程Concept model概念图
Industry产业

Touch for composite inspection用触觉检测复合材料

Developing event-based tactile sensing to detect surface defects in composite manufacturing.针对复合材料制造中的表面缺陷,开发事件驱动触觉传感器与机器人检测系统。

My contribution我的工作
As joint lead, I wrote the successful proposal and lead tactile hardware development.担任联合负责人,独立撰写获批申请;负责触觉传感器研发与硬件集成。
Status目前进展
Funded · in progress已获资助 · 正在进行
Funded through March 2027, with sensor prototypes and an ABB inspection pipeline under continued development.项目资助至 2027 年 3 月,已开展传感器原型和 ABB 检测流程验证,继续推进系统研发。
More about this work展开项目介绍

Independently wrote the successful proposal and lead hardware development for low-latency composite inspection.担任项目联合负责人,独立完成申请并获批,目前负责触觉传感器研发与硬件集成,面向复合材料表面检测。

Technical expertise技术能力

Robot systems and experiments机器人系统与实验

Core tools常用工具

  • Python
  • C / C++
  • PyTorch
  • OpenPI
  • ROS / ROS 2
  • Linux
  • Git

VLA fine-tuning & evaluationVLA 微调与策略评测

I completed three π0.5-DROID LoRA experiments, integrating paired tactile RGB as an additional image input and building checks for data quality and training/inference consistency. My other model work includes NeuroTac SCNNs, Sinabs deployment on Speck2f, and SNN pruning and quantisation research.完成三组 π0.5-DROID LoRA 实验,将双路触觉 RGB 作为额外图像接入,并建立数据质量与训练/推理一致性检查;其他模型工作包括 NeuroTac SCNN、通过 Sinabs 部署 Speck2f,以及 SNN 剪枝与量化研究。

  • LoRA
  • π0.5-DROID
  • Sinabs
  • snnTorch

Robot systems机器人系统搭建

I lead the VLA workstream on a dual-Franka leader–follower platform, connecting multi-view and tactile RGB with robot state and action data. The system uses native libfranka teleoperation, a DROID impedance-control interface and a documented RTX 5090 inference setup.负责双 Franka 主从平台的 VLA 路线,将多视角与触觉 RGB 接入机器人状态、动作数据;系统采用原生 libfranka 遥操与 DROID 阻抗控制接口,并已搭建 RTX 5090 推理环境。

  • Franka
  • libfranka
  • ZED 2i
  • RealSense D435

Tactile hardware & experiments触觉硬件与实验

I designed TacTip / NeuroTac housings, optical mounts and robot flanges in Fusion 360, then fabricated and integrated PolyJet / FDM prototypes. I use human and robot experiments to evaluate tactile perception across exploratory motions, speeds and contact depths.使用 Fusion 360 设计 TacTip / NeuroTac 壳体、光学支架与机械臂法兰,完成 PolyJet / FDM 原型制造与末端集成;通过人类与机器人实验,评估探索动作、运动速度和接触深度变化下的触觉感知表现。

  • NeuroTac
  • Fusion 360
  • PolyJet / FDM
  • Speck2f

Code you can inspect可以直接查看的代码与材料

Research materials and a contribution in review.公开实验材料,以及正在参与的开源改进。

Research materials公开研究材料

Human texture exploration人类触觉探索实验

Experimental materials, acquisition code and force/motion data accompanying my work on human exploration strategies.整理人类纹理探索实验的材料、采集代码与力和运动数据,便于了解论文背后的实验过程。

View repository查看代码仓库

Pull request · under review开源 PR · 审查中

REA · TypeScript analysisREA · TypeScript 分析修复

A fix for CommonJS exports hidden by TypeScript wrappers, with regression tests for deletion, shadowing and detached receivers. PR #4784 was still open on 6 November 2026.修复 TypeScript 类型包装导致的 CommonJS 导出识别问题,补充删除操作、变量遮蔽和引用分离的回归测试。截至 2026 年 11 月 6 日,PR #4784 尚未合并。

Read the pull request查看修改与审查记录

Research研究

Tactile perception and robot learning触觉感知与机器人学习

My PhD studies how exploratory movements affect tactile perception. I am also working on using touch in robot policies and composite inspection.我的博士研究主要看触摸动作如何影响感知;现在也在研究怎样把触觉用到机器人操作和复合材料检测里。

Exploratory motions触觉探索动作

Concept study · not experimental data交互示意 · 非实验数据

Embodied AI & robot control具身智能与机器人控制

Tactile feedback for manipulation and inspection操作与检测中的触觉反馈

I adapt VLA policies to use tactile images and work on tactile inspection of composites. This includes multimodal demonstrations, policy fine-tuning and robot-control interfaces.一部分工作是给 VLA 接入触觉图像,另一部分是用触觉检测复合材料缺陷。具体涉及多模态示教、策略微调和机器人控制接口。

Perception & active exploration感知与主动探索

Human and robot texture exploration人类与机器人的纹理探索

I study how movement, speed and contact conditions affect texture perception, using human experiments and neuromorphic tactile sensors.我通过人体实验和神经形态触觉传感器,研究动作、速度和接触条件怎样影响纹理感知。

Publications论文

Selected papers on touch触觉研究论文选

Studies of human exploration speed and robotic movement strategies, and a review of neuromorphic touch.关于人类探索速度、机器人探索动作的两项研究,以及一篇神经形态触觉综述。

  1. 01

    Li, A., Brayshaw, G., Lu, Y., & Ward-Cherrier, B.

    Velocity Modulation in Robotic Texture Exploration Based on Human Perceptual Dimensions

    IEEE-RAS Humanoids · 2025First author第一作者
  2. 02

    Xu, X.*, Li, A.*, & Ward-Cherrier, B.

    Exploratory Movement Strategies for Texture Discrimination with a Neuromorphic Tactile Sensor

    IEEE/RSJ IROS · 2025Equal contribution共同一作
  3. 03

    Liu, T., Brayshaw, G., Li, A., Xu, X., & Ward-Cherrier, B.

    Neuromorphic touch for robotics — A review

    Neuromorphic Computing and Engineering · 2025Open-access review开放获取综述

Personal个人

Outside the lab实验室之外

I play Dota 2 and like taking landscape photos when I travel.平时我会玩 Dota 2,旅行时喜欢拍风景。

Travel illustration · inspired by places I have visited旅行插画 · 灵感来自我去过的地方

About关于

Education and work教育与工作经历

Before my PhD, I did a master's in robotics. I've taught university robotics courses and worked in robot testing and technical support at Dobot.读博前我读的是机器人学硕士。我教过大学机器人课程,也在越疆做过真机测试和技术支持。

About关于View experience →查看经历 →

Journeys足迹

Places I have visited去过的地方

Paris, Delft, Corfu... a map of places I have visited.巴黎、代尔夫特、科孚岛……去过的地方,先在地图上记下来。

See the journeys查看足迹